Boston Dynamics equips Atlas with wheels to test its motors
Boston Dynamics has transformed Atlas into a wheeled research platform to evaluate the performance of its body control algorithm and actuators under high loads.
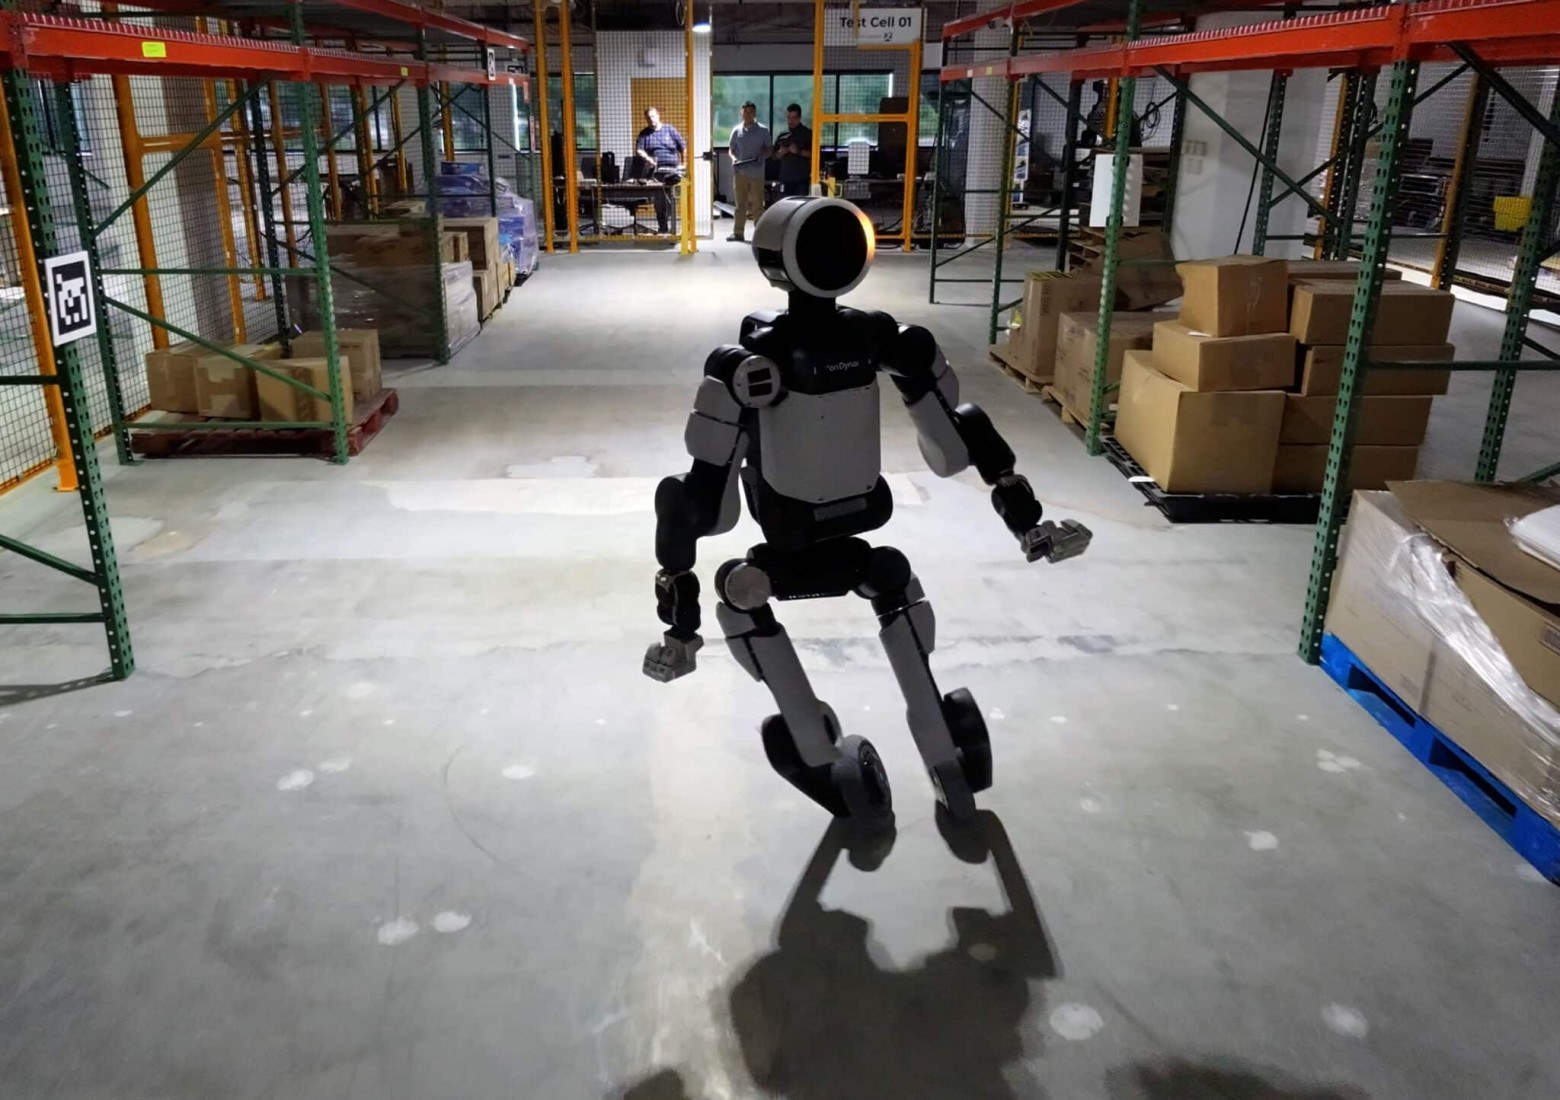
For the retrofit, a specially manufactured adapter was used: it allowed a standard scooter rim to be attached to the robot’s standard 'ankle' assembly. This is the only new component in the design. The company notes that due to Atlas’s initial focus on mass production and easy maintenance, such a modification is comparable to changing a bicycle wheel.
The wheeled mode enables continuous loading of the actuators: during acceleration, turning, and braking, the motors operate across the full range of torque and speed while bearing a real load. In the software model, each wheel was represented as an 'ankle' capable of continuous rotation.
For reinforcement learning, developers adjusted the reward function, command range, and posture stabilization methods. After this, Atlas independently mastered smooth rolling while maintaining stability. Some movements were based on human motion capture data: instead of sliding its legs, the algorithm learned to rotate the wheels and traverse sections by rolling.
The robot performed a 360-degree spin jump on its first attempt. The algorithm tracked a pre-recorded human trajectory, and before the jump, the lower part of the torso quickly adjusted to the required position using rolling. Boston Dynamics also noted that the wheel version’s surface grip differs from Atlas’s behavior on 'legs.'
Early project developments are already being integrated into the robot’s standard configuration. Previously, the company introduced a four-fingered hand for Atlas with 13 degrees of freedom and direct drive.